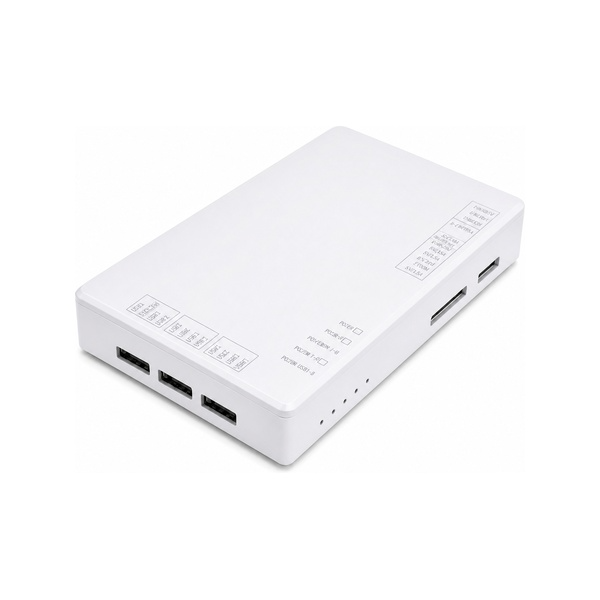
HB59 OEM GNSS Receiver Board — Septentrio AsteRx-m3 Pro+
OEM GNSS receiver board with Ethernet for system integration
- Septentrio AsteRx-m3 Pro+, 544 hardware channels
- Centimetre-level RTK: 0.6 cm + 0.5 ppm, 7 s initialization
- Dual-antenna heading 0.15° and pitch/roll 0.25° (1 m baseline)
- Up to 100 Hz position and measurements, <10 ms latency
- AIM+ anti-jamming and Galileo OSNMA anti-spoofing
- Ethernet, 3 × UART, USB Type-C and microSD up to 32 GB
- Board size 71.8 × 50.2 × 12.5 mm, 4.5–12 V input
No forms to fill in — we reply within one business day.
OEM GNSS receiver board for base, rover and heading
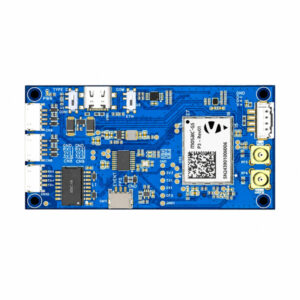
The Eview HB59 is a multi-frequency OEM GNSS receiver board built around the Septentrio AsteRx-m3 Pro+. It is made for engineers who build GNSS into their own machines, enclosures and control systems. One board can work as an RTK GNSS receiver rover, as a base station, or with two antennas for heading and pitch or roll. The HB59 is the board-level sibling of the HB10 dual-antenna receiver: it uses the same GNSS engine and adds Ethernet for system integration. It is part of our AsteRx-m3 GNSS boards.
RTK positioning and dual-antenna heading
The AsteRx-m3 Pro+ tracks GPS, GLONASS, Galileo, BeiDou, QZSS, NavIC and SBAS on multiple frequencies with 544 hardware channels. RTK accuracy is 0.6 cm + 0.5 ppm horizontal and 1 cm + 1 ppm vertical, with a typical 7 s initialization. With a second antenna on the AUX1 input, the HB59 gives 0.15° heading and 0.25° pitch or roll at 1 m antenna spacing, and 0.03° / 0.05° at 5 m, without the vehicle having to move. See how dual-antenna GNSS heading works.
100 Hz output with low latency
Position and raw measurements are available at up to 100 Hz (1 Hz by default), with latency below 10 ms for 99.9% of epochs. This suits fast control loops in autonomous vehicles, machine control and flight systems. LOCK+ keeps tracking stable under strong vibration and fast movement.
AIM+ anti-jamming and OSNMA anti-spoofing
Septentrio AIM+ detects and suppresses narrowband and wideband interference, and Galileo OSNMA authenticates satellite navigation data to protect against spoofing. IONO+ protects RTK during ionospheric scintillation, APME+ reduces multipath near buildings and metal structures, and RAIM+ monitors position integrity. Learn more about anti-jamming GNSS receivers and OSNMA anti-spoofing.
Ethernet, serial and logging for integration
The HB59 board carries Ethernet, three UARTs (115200 bps to 4 Mbps), USB 2.0 on Type-C, a 1PPS output, an event input, reset, and a microSD slot for raw data logging up to 32 GB. It accepts and outputs RTCM v2.x/v3.x and CMR/CMR+ corrections, and outputs NMEA 0183 and Septentrio SBF. The board runs from 4.5–12 V DC at about 1.6 W and operates from -40 °C to +85 °C. Firmware and manuals are on our firmware downloads page.
Applications
- Autonomous robots and vehicles: centimetre position and heading for unmanned ground vehicles and AGVs.
- Industrial drones: 100 Hz RTK and heading for flight control and mapping payloads.
- Construction and mining: machine control and guidance in harsh, high-multipath sites.
- Precision agriculture: auto-steering and implement control with low-latency RTK.
- Marine: GNSS heading and position for vessels and unmanned surface vehicles.
- Deformation monitoring: networked reference and monitoring stations over Ethernet.
Frequently asked questions
What is the difference between the HB59 and the HB10?
Both use the Septentrio AsteRx-m3 Pro+ and give the same RTK, heading and 100 Hz performance. The HB10 is a ready-to-use receiver; the HB59 is an OEM board that adds Ethernet for system integration.
Can the HB59 be used as an RTK base station?
Yes. The HB59 can be configured as a base or a rover. As a base it outputs RTCM v2.x/v3.x or CMR/CMR+ corrections over serial or Ethernet. See our guide to NTRIP, RTCM and RINEX integration.
Does the HB59 need two antennas?
No. With one antenna on the MAIN input it gives RTK position. Add a second antenna on AUX1 for heading and pitch or roll. Both inputs supply 3.0–5.5 V antenna bias, 150 mA maximum.
What power supply does the HB59 need?
Use a 4.5–12 V DC supply. Typical current is 330 mA at 5 V (about 1.6 W). Ripple on VCC should stay below 50 mV.
How do I get the full HB59 datasheet or a quote?
Email sales@gnss-solutions.com for the complete datasheet with pin-out and drawings, or ask a quote with your application and quantity.
Related reading
HB59 specifications
| GNSS engine | Septentrio AsteRx-m3 Pro+, 544 hardware channels |
|---|---|
| GNSS signals | GPS L1C/A, L1C, L2C, L2P(Y), L5 · GLONASS L1C/A, L2C/A, L2P, L3 · Galileo E1, E5a, E5b · BeiDou B1I, B1C, B2a, B2I, B3I · QZSS L1C/A, L1C, L2C, L5 · NavIC L5 · SBAS |
| RTK accuracy (RMS) | 0.6 cm + 0.5 ppm horizontal, 1 cm + 1 ppm vertical |
| Standalone / SBAS / DGNSS accuracy | 1.2 m / 0.6 m / 0.4 m horizontal; 1.9 m / 0.8 m / 0.7 m vertical |
| RTK initialization | 7 s |
| Heading / pitch-roll accuracy | 0.15° / 0.25° (1 m baseline); 0.03° / 0.05° (5 m baseline) |
| Velocity accuracy | 0.03 m/s |
| Maximum update rate | 100 Hz position and measurements |
| Latency | <10 ms (99.9%) |
| Time to first fix | Cold <45 s, warm <20 s, reacquisition 1 s |
| Timing accuracy | xPPS 5 ns, event <20 ns |
| Data formats | RTCM v2.x/v3.x and CMR v2.0/CMR+ in/out, NMEA 0183 v3.01/v4.0, Septentrio SBF |
| Interfaces | Ethernet, 3 × UART (115200 bps–4 Mbps), USB 2.0 Type-C, microSD up to 32 GB, 1PPS, event input |
| Power | 4.5–12 V DC, 330 mA typical at 5 V; antenna bias 3.0–5.5 V, 150 mA max |
| Operating temperature | -40 °C to +85 °C |
| Dimensions | 71.8 × 50.2 × 12.5 mm |
| Complete datasheet | On request: sales@gnss-solutions.com |
Product datasheet
The complete datasheet (GNSS signals, interfaces, pin-out, electrical and environmental specifications) is available on request. Email sales@gnss-solutions.com with the product name and your application.
Support documentation
Email sales@gnss-solutions.com for a quote, user manuals or integration support.