DroneX 2026: Resilient GNSS for Inspection Drones, AMRs and eVTOL
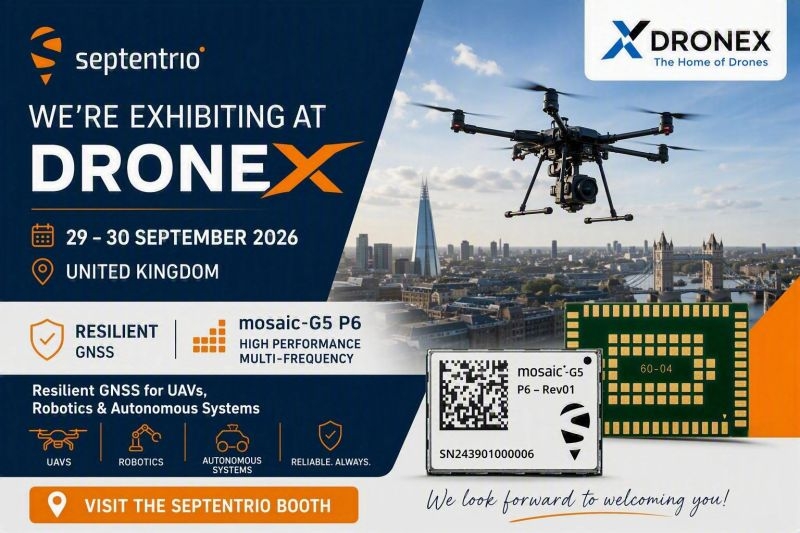
Image credit: Septentrio — DroneX 2026 event banner (septentrio.com).
DroneX 2026 puts the module layer that decides whether an autonomous platform holds its position in front of the people who build them, and Septentrio’s answer on the booth is the multi-frequency mosaic-G5 P6. The show runs 29–30 September in the United Kingdom, with Septentrio presenting compact, low-power GNSS for UAVs, robotics and autonomous systems alongside the DroneX programme.
Three platform classes dominate that audience, and they fail for different reasons. If you build any of them, the useful question is not how accurate a receiver is in open sky — it is what happens on the third pass over a substation, under a racking canopy, or in a low city canyon. This article maps those failure modes onto concrete receiver choices.
Where Each Platform Class Actually Breaks Down
| Platform class | Operating environment | Dominant failure mode | What the receiver must deliver |
| Inspection drone | Substations, transmission corridors, rail and bridges | Multipath and in-band interference during short, repeated hover windows | Fast re-fix, interference mitigation, minimal mass and current draw |
| AMR / ground robot | Warehouse aisles, port aprons, industrial yards | Multipath from steel and racking, plus long GNSS outages under cover | Rapid re-acquisition after shadowing, dependable heading, fusion-friendly output |
| eVTOL / UAM | Urban canyons, vertiports, low-altitude corridors | Urban multipath, deliberate jamming, undetected integrity faults | Integrity monitoring, dual-antenna heading, strong anti-jamming margin |
What a Low-SWaP Multi-Frequency Module Changes
Multi-frequency tracking has been normal in survey equipment for years; the constraint was always what it costs in size, weight and power once you leave a tripod. A compact module such as the mosaic-G5 P6 moves that trade-off. Multi-frequency resilience stops being the feature you cut when the platform gets small, and RF interference — the failure mode that arrives as a slow drift or a lost fix rather than a clean error — becomes something the receiver is designed to fight from the outset.
For integrators this mostly appears as headroom: room to keep a heading solution, a second antenna or a heavier payload; room to run a higher update rate without eating the power budget. On an airframe that inspects the same asset every week next to high-voltage equipment, that headroom is what turns a marginal link into a dependable one.
Eview Receivers Built on Septentrio Engines
The same silicon on the DroneX booth drives our range — Eview hardware, Septentrio Inside. Matching platform class to engine is the fastest way to narrow the choice:
| Best for | Eview receiver | Septentrio engine | Why it fits |
| Mass-critical UAV | HB52 / HB52H | mosaic-G5 | Ultralight RTK receiver for airframes where every gram of the GNSS chain counts |
| General UAV and robot integration | HB6 / HB6 Pro | mosaic-X5 or mosaic-H | Boxed receiver in single- or dual-antenna form, simpler to mount than a bare board |
| Heading-reliant platform | HB50H | mosaic-H | Dedicated heading receiver for platforms that need yaw, not only position |
| RTK and heading in one module | HB51 | mosaic-G5 P3H | Combines positioning and heading in a single module |
| AMR and machine integration | HB10 | AsteRx-m3 Pro+ | Anti-interference positioning and orientation for ground platforms |
| Space-constrained builds | HBEV322 / HBEV322H | mosaic-G5 | Compact RTK receiver carrying the same resilience story |
| Antenna side | EV210 and EV220 | — | UAV GNSS antennas matched to the receiver line |
Resilience Is the Spec That Gets Underestimated
Accuracy figures are easy to compare and largely irrelevant once a platform is working in a hostile RF environment. Interference mitigation, integrity monitoring and jamming margin are what separate a receiver that degrades gracefully from one that reports a confident wrong answer. Our AIM+ explainer covers the mitigation side, and the Jammertest 2025 results show how the technology behaves under deliberate interference rather than in a lab.
Two application pages are worth reading alongside this one if you are specifying for aerial inspection or autonomous ground work: UAV GNSS and robotics GNSS.
Frequently asked questions
How does multipath affect an inspection drone differently from an AMR?
An inspection drone meets multipath in bursts while hovering or passing close to a structure, so fast re-fix and interference mitigation matter most. An AMR meets it continuously in aisle and yard environments, and its harder problem is re-acquiring a fix after long shadowing under cover, which makes heading and a fusion-friendly output the priority.
Which Eview receivers suit eVTOL and advanced air mobility?
Dual-antenna options such as HB6 Pro (mosaic-X5 or mosaic-H) plus the heading-focused HB50H and HB51 cover the yaw requirement, while HB52 and HB52H cover mass-critical airframes. The choice turns on whether the flight controller needs heading in hover and how much integrity monitoring the certification path expects.
What does the mosaic-G5 P6 announcement change for existing integrations?
It widens the size, weight and power budget available for multi-frequency tracking, so integrators who previously accepted a single-frequency module to save mass and current can now keep multi-frequency resilience. Migration becomes an engine and firmware question rather than a platform redesign.
Next step: match a receiver to your platform
Send us the platform class, mass and power budget, accuracy and integrity targets, and the correction source you intend to use. We will reply with a specific receiver and antenna recommendation plus a quote. Start from the UAV GNSS or robotics GNSS range, or contact Eview GNSS directly.